
The ROS2 Learning Notes
Brief
These are my notes on ROS2. The software and hardware used throughout them is:
- ROS2 Jazzy Jalisco LTS
- Ubuntu 24.04.3 LTS
- Raspberry Pi 5B (4GB)
Most of these notes were written with reference to the following sites and video tutorials:
- The official ROS2 Jazzy documentation: ROS 2 Documentation — ROS 2 Documentation: Jazzy documentation
- The ROS2 online course by Zhao Xuzuo, lead author of the ROS Robot Theory and Practice textbook published by Tsinghua University Press: Mengshi Boot Camp video collection · ROS2 Theory and Practice, Core Chapters
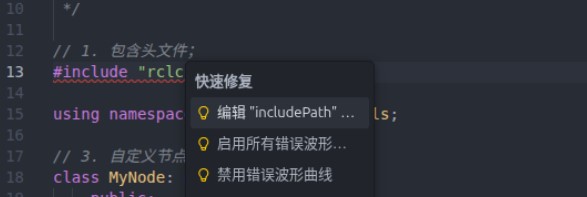
VSCode reports a header-file error while writing C++ files
You can go through the “Edit includePath...” option:
Find the “Include path” option:
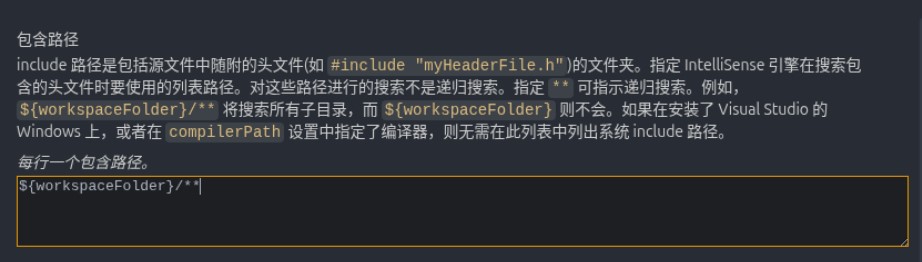
Add this on a new line:
/opt/ros/jazzy/include/**and that's it.
No completion suggestions while writing C++ files
Press Ctrl+Shift+P(Windows/Linux) or Cmd+Shift+P(Mac), type C/C++: Edit Configurations (UI) and pick that command. In the configuration panel that pops up you don't need to change anything — just click the save button in the top right. VSCode then generates a c_cpp_properties.json file in the .vscode folder at the project root. You can then edit c_cpp_properties.json and add "compilerPath" inside it:
{
    "configurations": [
        {
            "name": "Linux",
            "includePath": [
                "${workspaceFolder}/**",
                "/opt/ros/jazzy/include/**"
            ],
            "defines": [],
            "compilerPath": "/usr/bin/g++", // 👈 NEW!!
            "cStandard": "c17",
            "cppStandard": "gnu++17",
            "intelliSenseMode": "linux-gcc-x64"
        }
    ],
    "version": 4
}
Save it, restart VSCode, and you're set.
Snippets you can use
Here are some snippets you can use, covering node and launch:
// cpp.json
{
 "ros2_node_cpp":{
  "prefix": "ros2_node_cpp",
  "body": [
   " /*",
   "    Requirement:",
   "    Steps:",
   "        1. Include the header files;",
   "        2. Initialise the ROS2 client",
   "        3. Define the custom node class:",
   "",
   "        4. Call the spin function, passing in the node object pointer",
   "        5. Release resources.",
   " */",
   "",
   "// 1. Include the header files;",
   "#include \"rclcpp/rclcpp.hpp\"",
   "",
   "// 3. Define the custom node class:",
   "class MyNode: public rclcpp::Node{",
   "    public:" ,
   "        MyNode() : Node(\"mynode_node_cpp\"), count_(0)",
   "        {",
   "",
   "        }",
   "};",
   "",
   "int main(int argc, char *argv[])",
   "{",
   "    // 2. Initialise the ROS2 client",
   "    rclcpp::init(argc, argv);",
   "    // 4. Call the spin function, passing in the node object pointer.",
   "    rclcpp::spin(std::make_shared<MyNode>());",
   "    // 5. Release resources;",
   "    rclcpp::shutdown();",
   "    return 0; ",
   "} "
  ],
  "description": "ros2 node user snippets"
 },
}
// python.json
{
"ros2 node": {
"prefix": "ros2_node_py",
"body": [
"\"\"\" ",
" Requirement:",
" Flow:",
" 1. Import the packages;",
" 2. Initialise the ROS2 client;",
" 3. Define the custom node class;",
" ",
" 4. Call the spain function, passing in the node object;",
" 5. Release resources. ",
"",
"",
"\"\"\"",
"# 1. Import the packages;",
"import rclpy",
"from rclpy.node import Node",
"",
"# 3. Define the custom node class;",
"class MyNode(Node):",
" def __init__(self):",
" super().__init__(\"mynode_node_py\")",
"",
"def main():",
" # 2. Initialise the ROS2 client;",
" rclpy.init()",
" # 4. Call the spain function, passing in the node object;",
" rclpy.spin(MyNode())",
" # 5. Release resources. ",
" rclpy.shutdown()",
"",
"if __name__ == '__main__':",
" main()",
],
"description": "ros2 node"
},
"ros2 launch py": {
"prefix": "ros2_launch_py",
"body": [
"from launch import LaunchDescription",
"from launch_ros.actions import Node",
"# Classes wrapping terminal commands--------------",
"# from launch.actions import ExecuteProcess",
"# from launch.substitutions import FindExecutable",
"# Declaring and getting parameters-----------------",
"# from launch.actions import DeclareLaunchArgument",
"# from launch.substitutions import LaunchConfiguration",
"# Including files-------------------",
"# from launch.actions import IncludeLaunchDescription",
"# from launch.launch_description_sources import PythonLaunchDescriptionSource",
"# Grouping----------------------",
"# from launch_ros.actions import PushRosNamespace",
"# from launch.actions import GroupAction",
"# Events----------------------",
"# from launch.event_handlers import OnProcessStart, OnProcessExit",
"# from launch.actions import ExecuteProcess, RegisterEventHandler,LogInfo",
"# Getting the package's share directory path-------",
"# from ament_index_python.packages import get_package_share_directory",
"",
"def generate_launch_description():",
" ",
" return LaunchDescription([])"
],
"description": "ros2 launch"
}
}Important
This article was translated by Hermes Agent; the original text can be found at here. The translation is for reference only. Translation time: 2026-11-05